What is a force?
From kinematics to dynamics
So far, we’ve talked about how we can mathematically represent motion of a point particle: a particle has a position (where it is) and velocity $\vec{v}$ (how it’s moving). The rate of change of the velocity is the acceleration $\vec{a}$, which tells us how the motion changes over time.
If we know in advance how a particle’s motion changes over time (for example, if we know its constant acceleration) we can predict where the particle will be and how it will be moving at any future time.
This is a useful first step, but it clearly leaves a lot to be explained. What if we don’t know in advance how the motion changes? How do we predict the future motion of a particle if we don’t already know the acceleration? And more fundamentally, what causes motion to change in the first place?
Dynamics and Newton’s laws
In physics, predicting how the behavior of a system will change over time is called dynamics. The classical (as opposed to quantum) laws that describe dynamics of particles—how particles interact with one another and how their motion changes—are Newton’s laws.
Newton’s laws are based on the fundamental concept of force. To get started using Newton’s laws, we need to have some understanding of what a force is. The best explanation I can give you of what a force is:
a force is a “push” or a “pull” that one object exerts on another.
While this is an intuitive description, it’s not very precise. Before I move on to stating Newton’s laws, let me try to clarify this statement.
Contact forces vs. long-ranged forces
Even though I’m saying that a force is a “push or pull,” exerting a force does not require direct contact like when you push something with your hand.
Some forces, like the force you exert on a door by pushing or pulling it with your hand, are contact forces. Other forces are long-ranged forces and don’t require contact.
The most familiar example of a long-ranged force is gravity: the Earth exerts a gravitational force on you regardless of whether you are touching it or not. Another example of a long-ranged force is the electromagnetic force: a charged particle (like a proton) can exert a force on another charged particle (like an electron) even if they are not touching.
Fundamental forces
We can explain essentially all of our everyday experience using just two forces: the gravitational force and the electromagnetic force. These are fundamental forces: we can’t explain gravity or electromagnetism in terms of any more basic forces or interactions.
There are other fundamental interactions that are relevant for the physics of atomic nuclei and subatomic particles that we call the weak interaction and the strong interaction. The strong interaction is responsible for holding protons and neutrons together in atomic nuclei, while the weak interaction is responsible for certain types of radioactive decay (including some used in medical interventions and imaging).
Together, these four fundamental interactions (gravity, electromagnetism, weak, and strong) describe all observed phenomena.
Everyday forces
Aside from gravity, there are many different “everyday” forces we encounter. Here are just a few examples:
- Contact forces between surfaces (normal force and friction)
- Elastic forces in springs, tendons, rubber bands, etc.
- Fluid resistance (drag) forces
- Buoyant forces
All of these forces can be explained in terms of electromagnetic interactions between molecules and atoms.
Forces are vector quantities
A force naturally has a direction as well as a magnitude. If you push on an object, you exert a force in the direction of your push. The strength of the force is determined by how hard you push. As we know, a quantity that has both a magnitude and a direction is a vector quantity. We can represent any force as a vector $\vec{F}$.
The net force on an object is the vector sum of all of the forces acting on the object,
\[\vec{F}_{\mathrm{net}} = \vec{F}_{1} + \vec{F}_{2} + \ldots\]Remember: to add vectors, we add their components. So in an $x$-$y$ coordinate system, the components of the net force are
\[\begin{aligned} F_{\mathrm{net},x} &= F_{1,x} + F_{2,x} + \ldots\\ F_{\mathrm{net},y} &= F_{1,y} + F_{2,y} + \ldots \end{aligned}\]Newton’s laws and the first law
Newton’s laws are the three fundamental principles that connect the motion of a particle to the forces acting on it. They are:
- Newton’s first law (N1): In an inertial coordinate system, a particle with no net force acting on it has zero acceleration.
- Newton’s second law (N2): The acceleration of a particle is directly proportional to the net force acting on it.
- Newton’s third law (N3): If particle A exerts a force on particle B, then particle B exerts a force of the same magnitude but in the opposite direction on particle A.
Newton’s first law
Newton’s first law (N1) says that
Every object has a constant velocity unless a net force acts on it.
The essence of Newton’s first law is that maintaining motion does not require a force. A force is only required to change motion. In particular, there is no such thing as a “force of motion” that keeps an object moving.
Another way to state the first law is that
Every object has zero acceleration unless a net force acts on it.
Inertial coordinate systems
There are some situations in which an object can accelerate even when there is no net force acting on it. For example, consider a scenario like a bag of groceries sitting on a car seat. If you brake hard, the bag will accelerate forward and fall off of the seat.
Even though there is no force that pushes or pulls the bag, from our perspective inside the car, the bag accelerates, and Newton’s first law does not hold.
The issue is that we are observing the motion from an accelerating coordinate system, since the car is accelerating when we brake. A coordinate system that is not accelerating is called an inertial coordinate system, and an accelerating coordinate system is a non-inertial coordinate system.
Newton’s first and second laws only hold in inertial coordinate systems. If we observe the motion of the bag of groceries in an inertial coordinate system—for example, from the perspective of a stationary observer standing on the sidewalk—we see that the bag does not accelerate and Newton’s first law holds.
From the inertial observer’s point of view, the apparent acceleration inside the car is simply due to the fact that the car is slowing down, but the bag continues moving at a constant velocity until it hits the floor of the car.
We will always choose to work in inertial—non-accelerating, non-rotating—coordinate systems when we solve dynamics problems, so Newton’s laws will always hold for us.
Newton’s second law
Newton’s second law (N2) is the main dynamical law. It tells us that
An object’s acceleration is proportional to the net force acting on the object.
Written as an equation, Newton’s second law is
\[\vec{a} = \frac{\vec{F}_{\mathrm{net}}}{m}\]Since the net force and acceleration vectors are proportional to each other, an object’s acceleration points in the same direction as the net force acting on it.
This does not mean that an object has to move in the same direction as the net force on it. The net force determines the change in velocity (acceleration), not the velocity itself.
Mass
The constant of proportionality $m$ is a scalar called the mass. Mass tells us how objects respond to applied forces. If we apply the same net force to two objects, the object with greater mass will accelerate less.
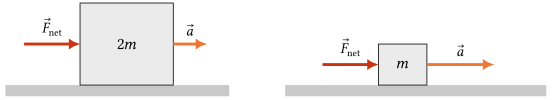
Units for mass and force
The SI unit of mass is the kilogram (symbol $\mathrm{kg}$). One kilogram is about $2.2$ pounds.
For the units in Newton’s 2nd law to be consistent, the unit of force must be the same as the units of $ma$. This combination of SI base units is called the newton ($\mathrm{N}$):
\[1\ \mathrm{N} = 1\ \mathrm{kg\,m/s^2}\]Some example forces in newtons:
- Weight of a laptop: $\approx 15\ \mathrm{N}$
- Maximum human bite force at molars: $\approx 300$–$600\ \mathrm{N}$
- Bending force to break a forearm bone: $\approx 1500\ \mathrm{N}$
- Thrust of Artemis II solid rocket boosters: $\approx 32\ \mathrm{MN}$